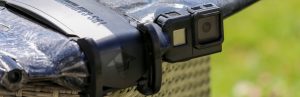
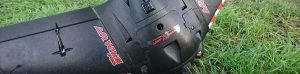
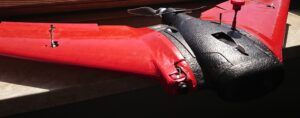
Description
The ZOHD Dart 250G developed a real hype in the community during the past few months. Not only because it can be built below the 250g limit to bypass some countries law regulations. But also, because of its very impressive flight performance and record braking endurance capabilities. Not to mention the low price point this plane can be build at. This setup will allow you to build a long range Dart 250G that is also great for beginners.
This specific Dart 250G setup is based on the PNP Version and uses all the stock components like Motor, ESC and Servos. The PnP Dart 250G is already good for beginners and long range. It also does not need any kind of airframe modification despite a little hole in the VTX cover to mount the antenna and maybe a tiny hole for the receiver antenna. Depending on your battery and VTX selection, it will be possible to keep the plane below the 250g limit but this will lower the long range capabilities a bit.
Flight Specs
Battery: 3S 1000mAh (fun flying); 2S 1600mAh (med. long range), 2S 3500mAh Li-Ion (extreme long range above 250g)
Top speed: 110kph
Stall speed: 25-30kph
Propeller: Stock 3x5x3 (3S); 5×5 (2S)
Rates: roll at 520°/S; pitch at 140°/s
Current draw: 1,8A cruise; 8A peak (depends on vtx power cunsumption too)
Flight Time: up to 30min on 3S; 45min on 2S; 90min on 2S Li-Ion
CG: on spot
Components
Airframe: ZOHD Dart 250G PNP Version
Motor: Stock Sunnysky 1406 @ 2600kV
ESC: Stock ZOHD 30A Wing ESC
Servos: Stock ZOHD 4.5g Nylon Gear
Flight Controller: Matek F411WSE
VTX: AKK FX3 600mW (>250g); TBS UNIFY PRO32 NANO 500mW+ (<250g) [No Smart Audio control up to INAV 2.5]
FPV Cam: Runcam Nano 2
Antenna: Lumenier Micro AXII MMCX (for TBS); Foxeer 5.8G Lollipop 3 (for AKK)
GPS: Beitan BN-220T
- AKK FX2 VTx
AKK FX3
Buy the AKK FX2 VTx from Banggood

FX3 is a small 5.8GHz VTx. It has 20 x 20 mm spaced holes to mount it on a Flight Controller stack. You attach the antenna with an MMCX connector.
- Beitian BN-220T GPS Module
Beitian BN-220T
Buy the Beitian BN-220T from Banggood

The Beitian BN-220T is a small, light GPS module that is ideally suited to an INAV model.
- Foxeer Lollipop 3 Antenna
Foxeer Lollipop 3
Buy the Foxeer Lollipop 3 SMA Version from Banggood
Buy the Foxeer Lollipop 3 MMCX Version from Banggood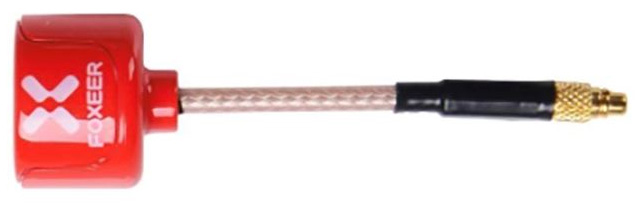
The Foxeer Lollipop 3 is a light weight, 5.8 GHz, circular polarised antenna. It weighs only 3.7 grams, has a gain of 2.5 dBi, and a VSWR less than 1.2.
- Lumenier Micro AXII Antenna
Lumenier Micro AXII
Buy the Lumenier Micro AXII from Banggood
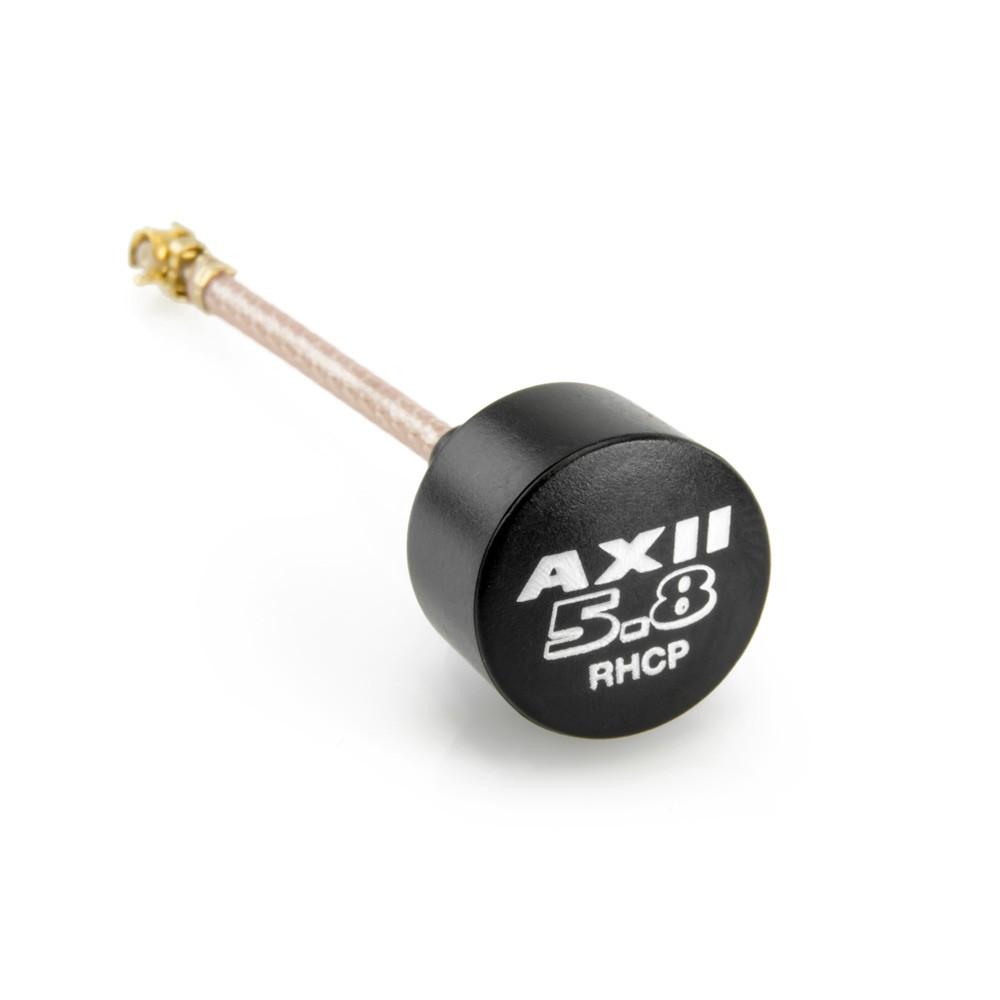
The Lumenier Micro AXII is a 5.8 GHz antenna with a U.FL connector. You can get it in RHCP or LHCP polarisation or a length of 30 mm or 60 mm. The antenna has a gain of 1.6 dBic.
- Matek F411-WSE
Matek F411-WSE
Buy the Matek F411-WSE on Banggood

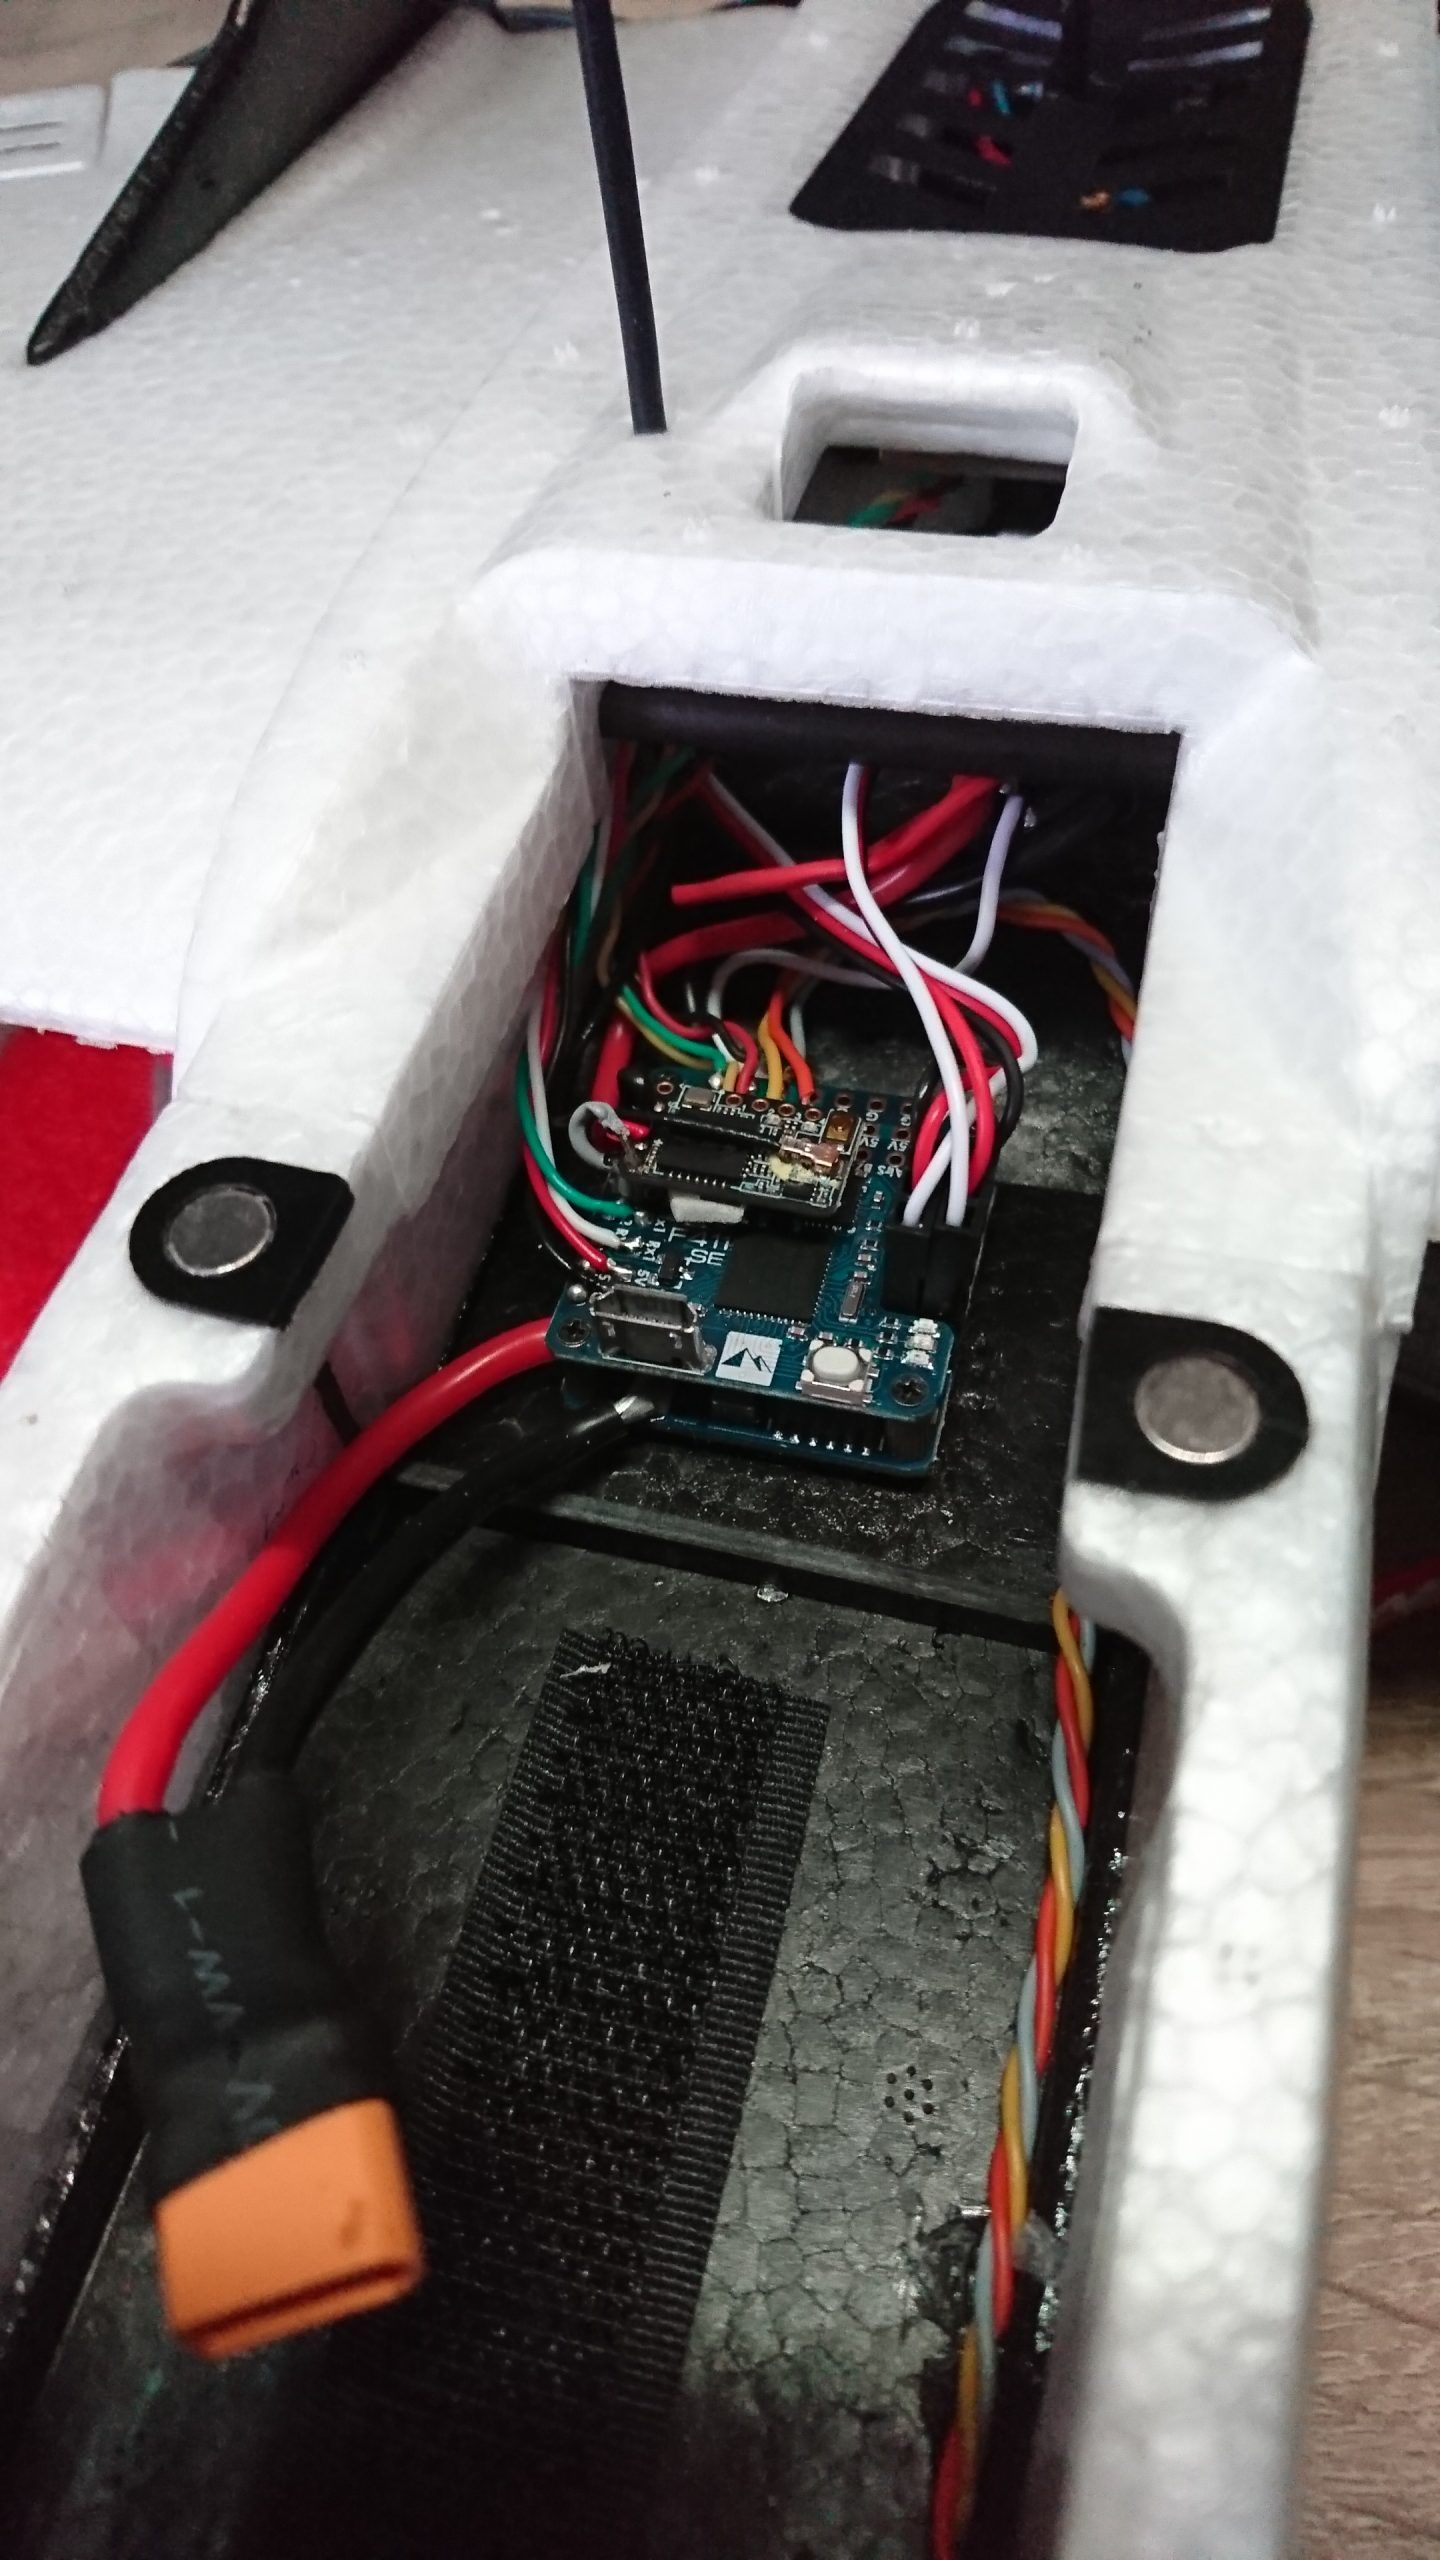
The Matek F411-WSE is a small and lightweight all-in-one wing flight controller. At only 28 mm square, 14 mm high, and with a weight of only 8.5 grams; it is a great choice for small builds. Even 250 gram builds can carry this FC.
- RunCam Nano 2 FPV Camera
RunCam Nano 2
Buy the RunCam Nano 2 from Banggood

The RunCam Nano 2 is a tiny 14 x 14 mm FPV camera with an M8 lens. It weighs 3.2 grams and has a 1/3″ 4:3 CMOS sensor.
- TBS Unify PRO32 Nano VTx
TBS Unify PRO32 Nano
Buy the TBS Unify PRO32 Nano here

The TBS Unify PRO32 Nano is one of the smallest and lightest 5.8 GHz VTx on the market. This VTx is a tiny 15 x 13 x 2 mm in size, and weighs 1 gram.
- ZOHD Dart 250G PnP
ZOHD Dart 250G PnP
Buy the ZOHD Dart 250G PnP from Banggood

The ZOHD Dart 250G may look small and inoffensive. But this lightweight model can be an FPV ninja! It is suitable for beginners, proximity flyers, and long range.
Video and Pictures




CLI Settings
SETTINGS FOR INAV 2.4
# servo mixer
smix reset
smix 0 3 0 80 0 -1
smix 1 3 1 65 0 -1
smix 2 4 0 -80 0 -1
smix 3 4 1 65 0 -1

# filter
set looptime = 1000
set gyro_sync = ON
set align_gyro = DEFAULT
set gyro_hardware_lpf = 42HZ
set gyro_lpf_hz = 30
set gyro_lpf_type = BIQUAD
set moron_threshold = 32
set gyro_notch1_hz = 0
set gyro_notch1_cutoff = 1
set gyro_notch2_hz = 0
set gyro_notch2_cutoff = 1
set gyro_stage2_lowpass_hz = 0
set gyro_stage2_lowpass_type = BIQUAD
set dyn_notch_width_percent = 8
set dyn_notch_range = MEDIUM
set dyn_notch_q = 120
set dyn_notch_min_hz = 60
set imu_acc_ignore_rate = 9
set imu_acc_ignore_slope = 0

# navigation settings for RTH
set nav_fw_cruise_thr = 1500
set nav_fw_min_thr = 1050
set nav_fw_max_thr = 2000
set nav_fw_bank_angle = 30
set nav_fw_climb_angle = 25
set nav_fw_dive_angle = 20
set nav_fw_pitch2thr = 22
set nav_fw_loiter_radius = 5000

# autolaunch
set nav_fw_launch_velocity = 300
set nav_fw_launch_accel = 1500
set nav_fw_launch_max_angle = 180
set nav_fw_launch_detect_time = 40
set nav_fw_launch_thr = 2000
set nav_fw_launch_idle_thr = 1200
set nav_fw_launch_motor_delay = 100
set nav_fw_launch_spinup_time = 100
set nav_fw_launch_min_time = 2000
set nav_fw_launch_timeout = 10000
set nav_fw_launch_max_altitude = 5000
set nav_fw_launch_climb_angle = 25

# tune
profile 1
set fw_p_pitch = 5
set fw_i_pitch = 10
set fw_ff_pitch = 48
set fw_p_roll = 2
set fw_i_roll = 7
set fw_ff_roll = 28
set tpa_rate = 60
set tpa_breakpoint = 1500
set max_angle_inclination_rll = 450
set max_angle_inclination_pit = 300
set roll_rate = 52
set pitch_rate = 14
SETTINGS FOR INAV 2.5
# servo mixer
smix reset
smix 0 3 0 80 0 -1
smix 1 3 1 65 0 -1
smix 2 4 0 -80 0 -1
smix 3 4 1 65 0 -1

# filter
set looptime = 1000
set gyro_sync = ON
set align_gyro = DEFAULT
set gyro_hardware_lpf = 188HZ
set gyro_lpf_hz = 30
set gyro_lpf_type = BIQUAD
set moron_threshold = 32
set gyro_notch1_hz = 0
set gyro_notch1_cutoff = 1
set gyro_notch2_hz = 0
set gyro_notch2_cutoff = 1
set gyro_stage2_lowpass_hz = 0
set gyro_stage2_lowpass_type = BIQUAD
set dynamic_gyro_notch_enabled = ON
set dynamic_gyro_notch_range = MEDIUM
set dynamic_gyro_notch_q = 120
set dynamic_gyro_notch_min_hz = 30
set imu_acc_ignore_rate = 9
set imu_acc_ignore_slope = 0

# navigation settings for RTH
set nav_fw_cruise_thr = 1500
set nav_fw_min_thr = 1050
set nav_fw_max_thr = 2000
set nav_fw_bank_angle = 30
set nav_fw_climb_angle = 25
set nav_fw_dive_angle = 20
set nav_fw_pitch2thr = 22
set nav_fw_loiter_radius = 5000

# autolaunch
set nav_fw_launch_velocity = 300
set nav_fw_launch_accel = 1500
set nav_fw_launch_max_angle = 180
set nav_fw_launch_detect_time = 40
set nav_fw_launch_thr = 2000
set nav_fw_launch_idle_thr = 1200
set nav_fw_launch_motor_delay = 100
set nav_fw_launch_spinup_time = 100
set nav_fw_launch_min_time = 2000
set nav_fw_launch_timeout = 10000
set nav_fw_launch_max_altitude = 5000
set nav_fw_launch_climb_angle = 25

# tune
profile 1
set fw_p_pitch = 5
set fw_i_pitch = 10
set fw_ff_pitch = 48
set fw_p_roll = 2
set fw_i_roll = 7
set fw_ff_roll = 28
set tpa_rate = 60
set tpa_breakpoint = 1500
set max_angle_inclination_rll = 450
set max_angle_inclination_pit = 300
set roll_rate = 52
set pitch_rate = 14
SETTINGS FOR INAV 2.6
# servo mixer
smix reset
smix 0 3 0 80 0 -1
smix 1 3 1 65 0 -1
smix 2 4 0 -80 0 -1
smix 3 4 1 65 0 -1

# filter
set looptime = 1000
set gyro_sync = ON
set align_gyro = DEFAULT
set gyro_hardware_lpf = 188HZ
set gyro_lpf_hz = 30
set gyro_lpf_type = BIQUAD
set moron_threshold = 32
set dynamic_gyro_notch_enabled = ON
set dynamic_gyro_notch_range = MEDIUM
set dynamic_gyro_notch_q = 120
set dynamic_gyro_notch_min_hz = 30
set imu_acc_ignore_rate = 8
set imu_acc_ignore_slope = 0

# navigation settings for RTH
set nav_fw_cruise_thr = 1500
set nav_fw_min_thr = 1050
set nav_fw_max_thr = 2000
set nav_fw_bank_angle = 30
set nav_fw_climb_angle = 25
set nav_fw_dive_angle = 20
set nav_fw_pitch2thr = 22
set nav_fw_loiter_radius = 5000

# autolaunch
set nav_fw_launch_velocity = 300
set nav_fw_launch_accel = 1500
set nav_fw_launch_max_angle = 180
set nav_fw_launch_detect_time = 40
set nav_fw_launch_thr = 2000
set nav_fw_launch_idle_thr = 1200
set nav_fw_launch_motor_delay = 100
set nav_fw_launch_spinup_time = 100
set nav_fw_launch_min_time = 2000
set nav_fw_launch_timeout = 10000
set nav_fw_launch_max_altitude = 5000
set nav_fw_launch_climb_angle = 25

# tune
profile 1
set fw_p_pitch = 5
set fw_i_pitch = 10
set fw_ff_pitch = 48
set fw_p_roll = 2
set fw_i_roll = 7
set fw_ff_roll = 28
set tpa_rate = 60
set tpa_breakpoint = 1500
set max_angle_inclination_rll = 450
set max_angle_inclination_pit = 300
set roll_rate = 52
set pitch_rate = 14Do you have a setup to share?
INAV Fixed Wing Group is a community. We all pull together to help everyone else. This build, like the others on this site, has come from a group member. Its here to help others get in the air and flying well. If you have a model that flies great; but, isn’t on this site, or has a different purpose to one that is. Please click the button below for details on how you can share your setup with the community